FTC SpiderTech

About Us

Spider-Tech is a driven four-person robotics team competing in the FIRST Tech Challenge, with the goal of becoming one of the top teams in the region.

Although the 2025-2026 season was our rookie year, we quickly made our mark, earning multiple awards and advancing all the way to the State Championship.

Our small but mighty team handles everything ourselves — design, hardware, software, and outreach — allowing us to move fast and innovate at every stage of the build process. We pride ourselves on creativity, precision, and relentless problem-solving under pressure.

This season, we will push ourselves to learn faster, build smarter, and compete harder than the year before. With a strong foundation already in place, we're just getting started on our journey to the top.

Meet the Team
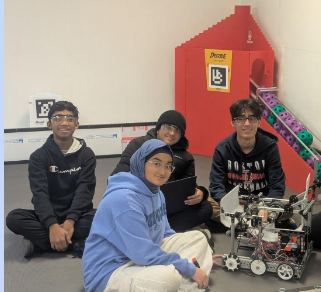
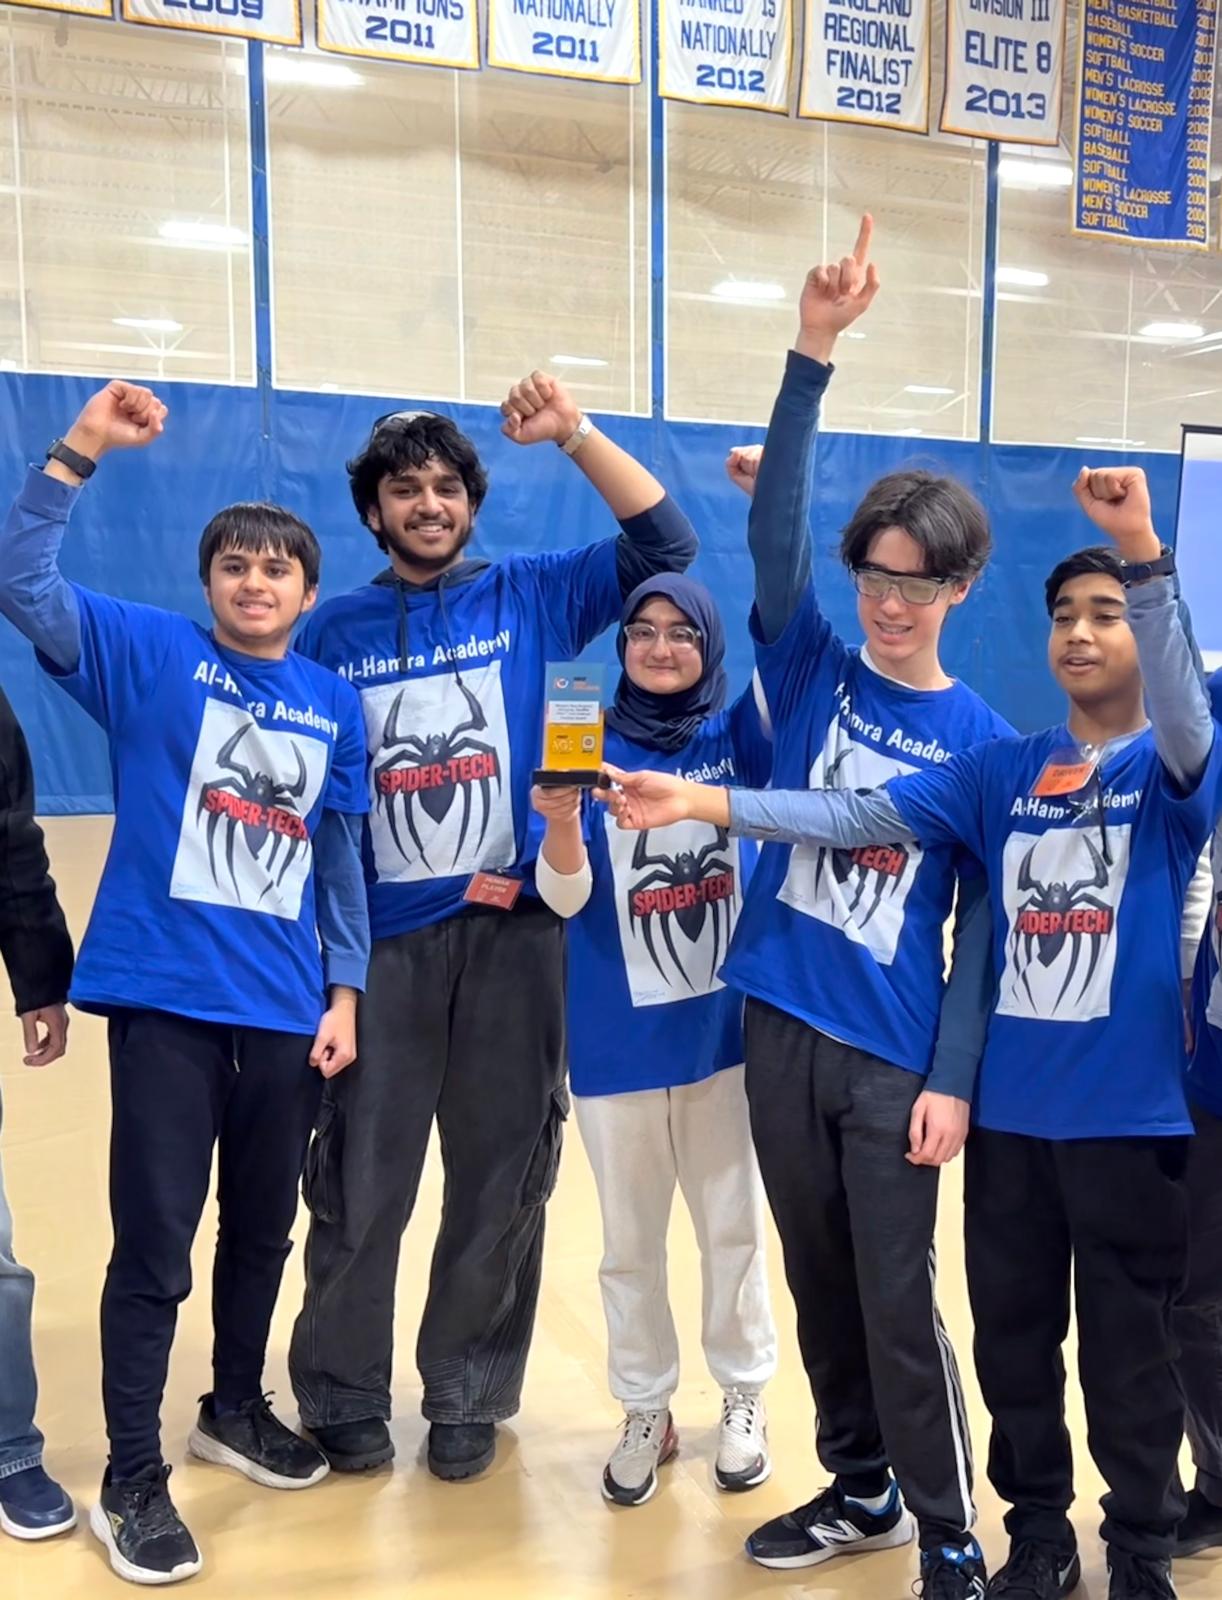
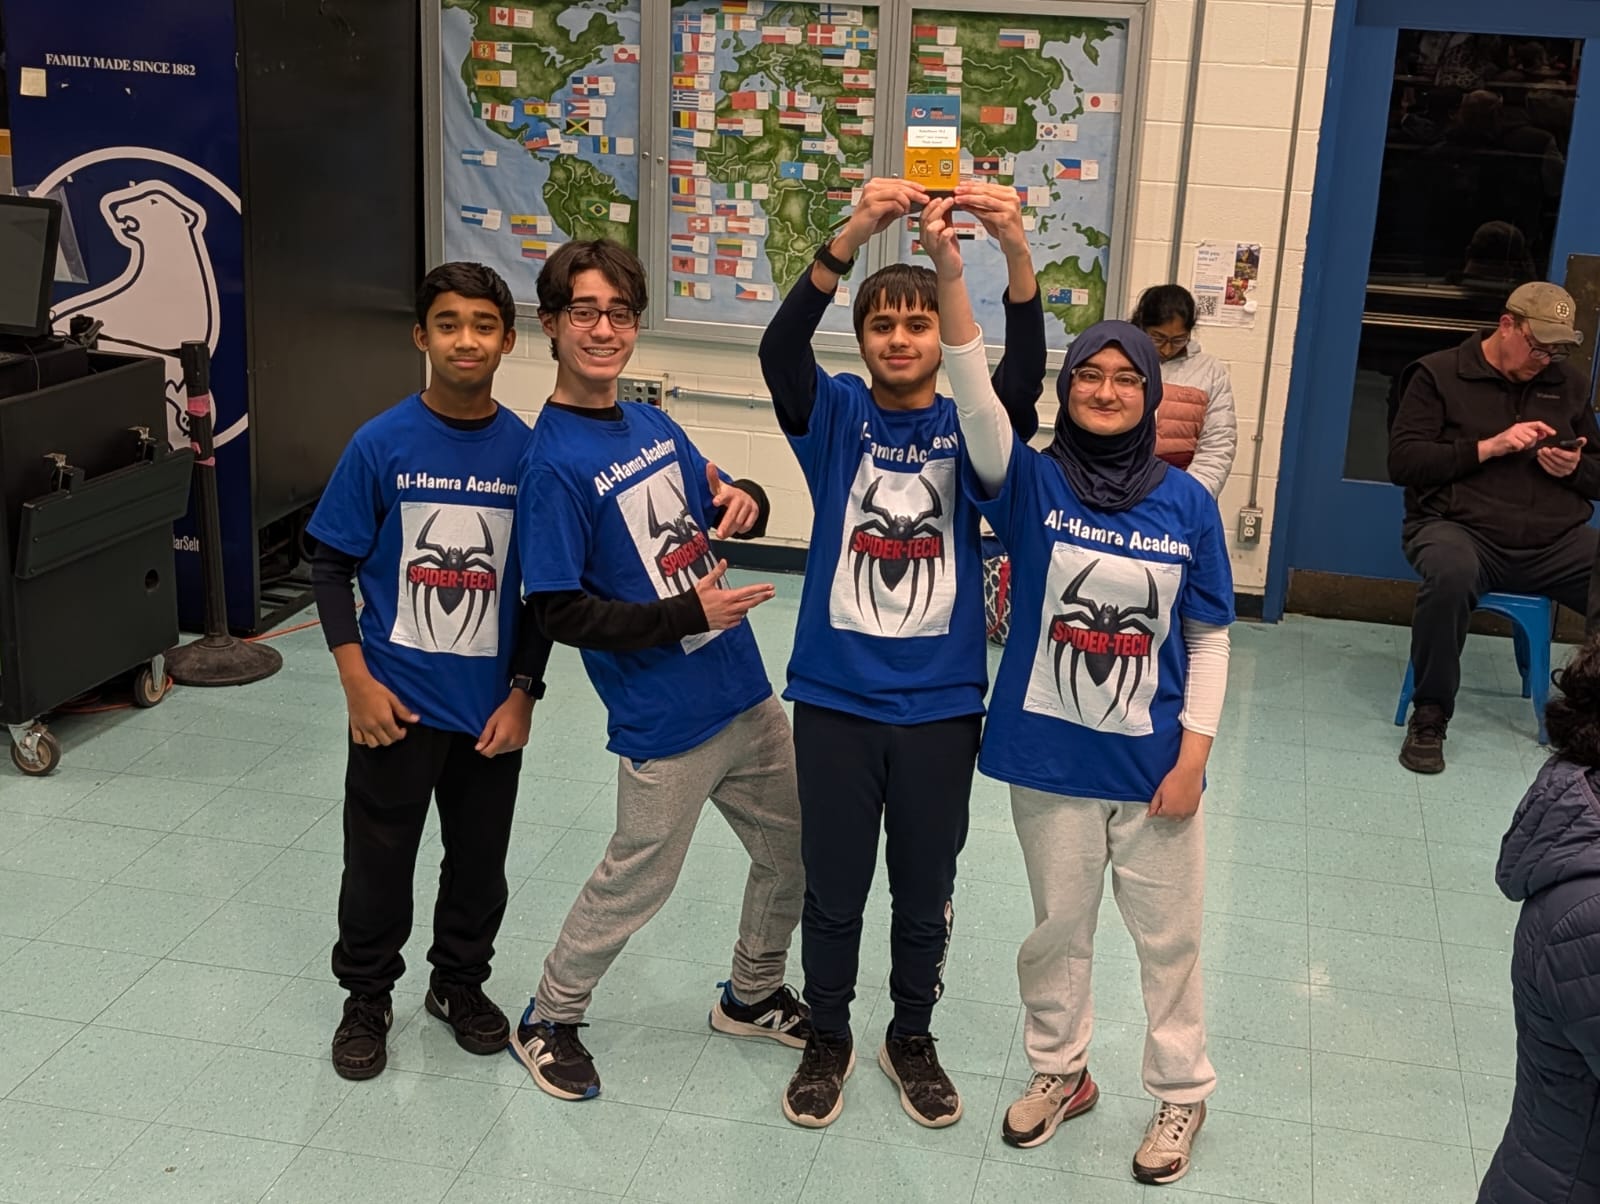
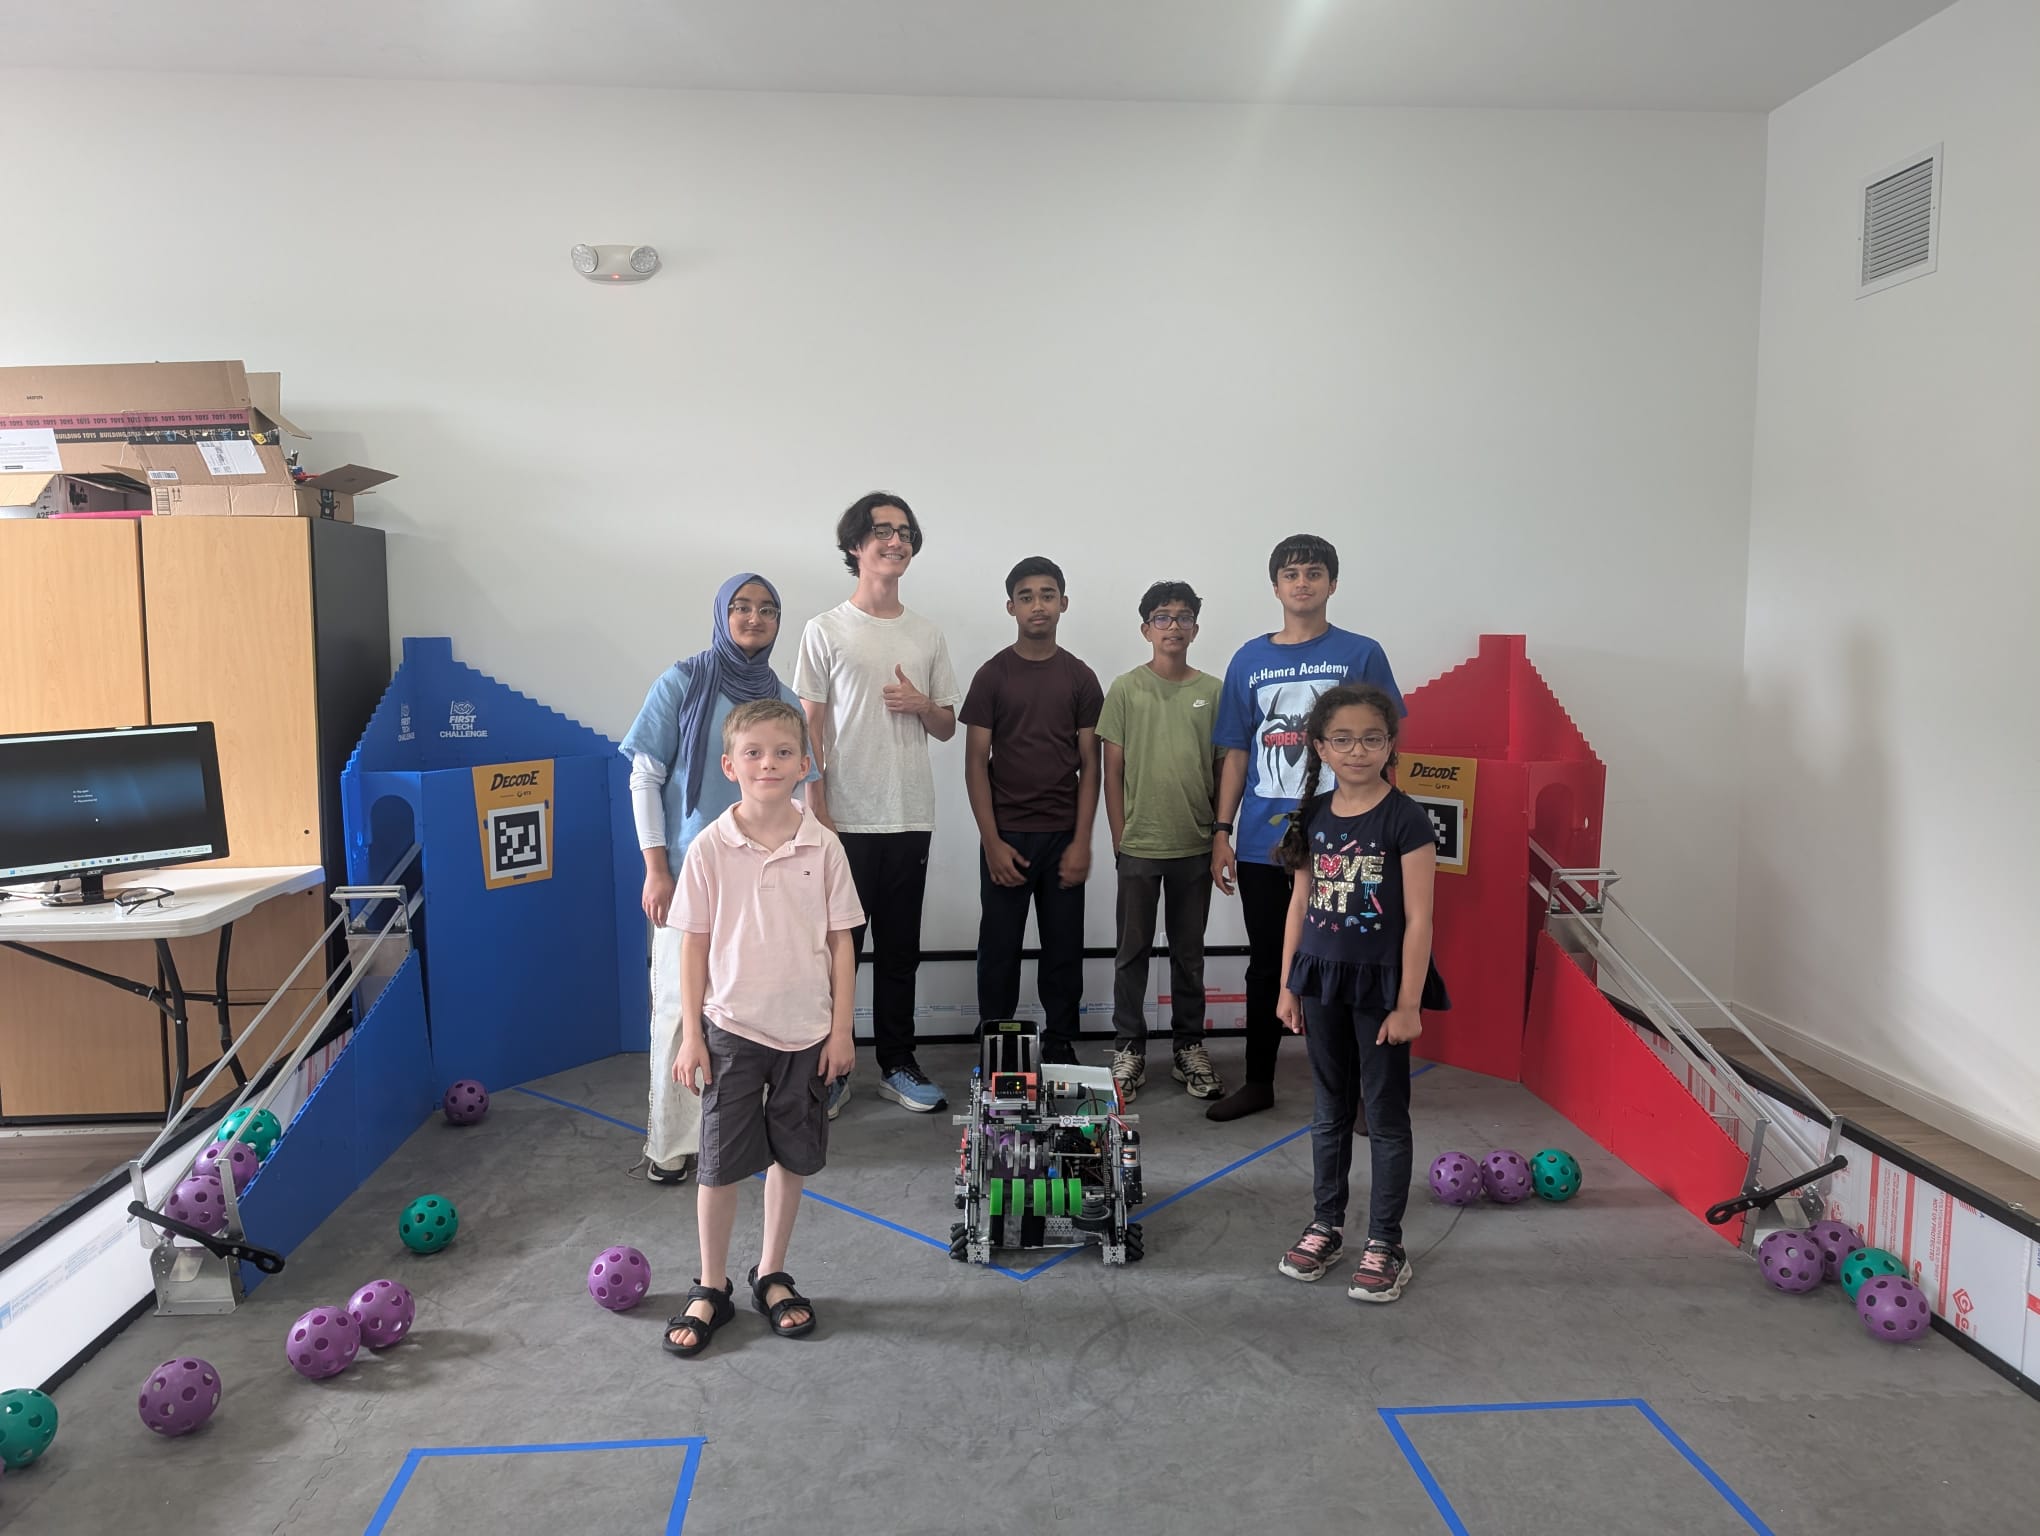
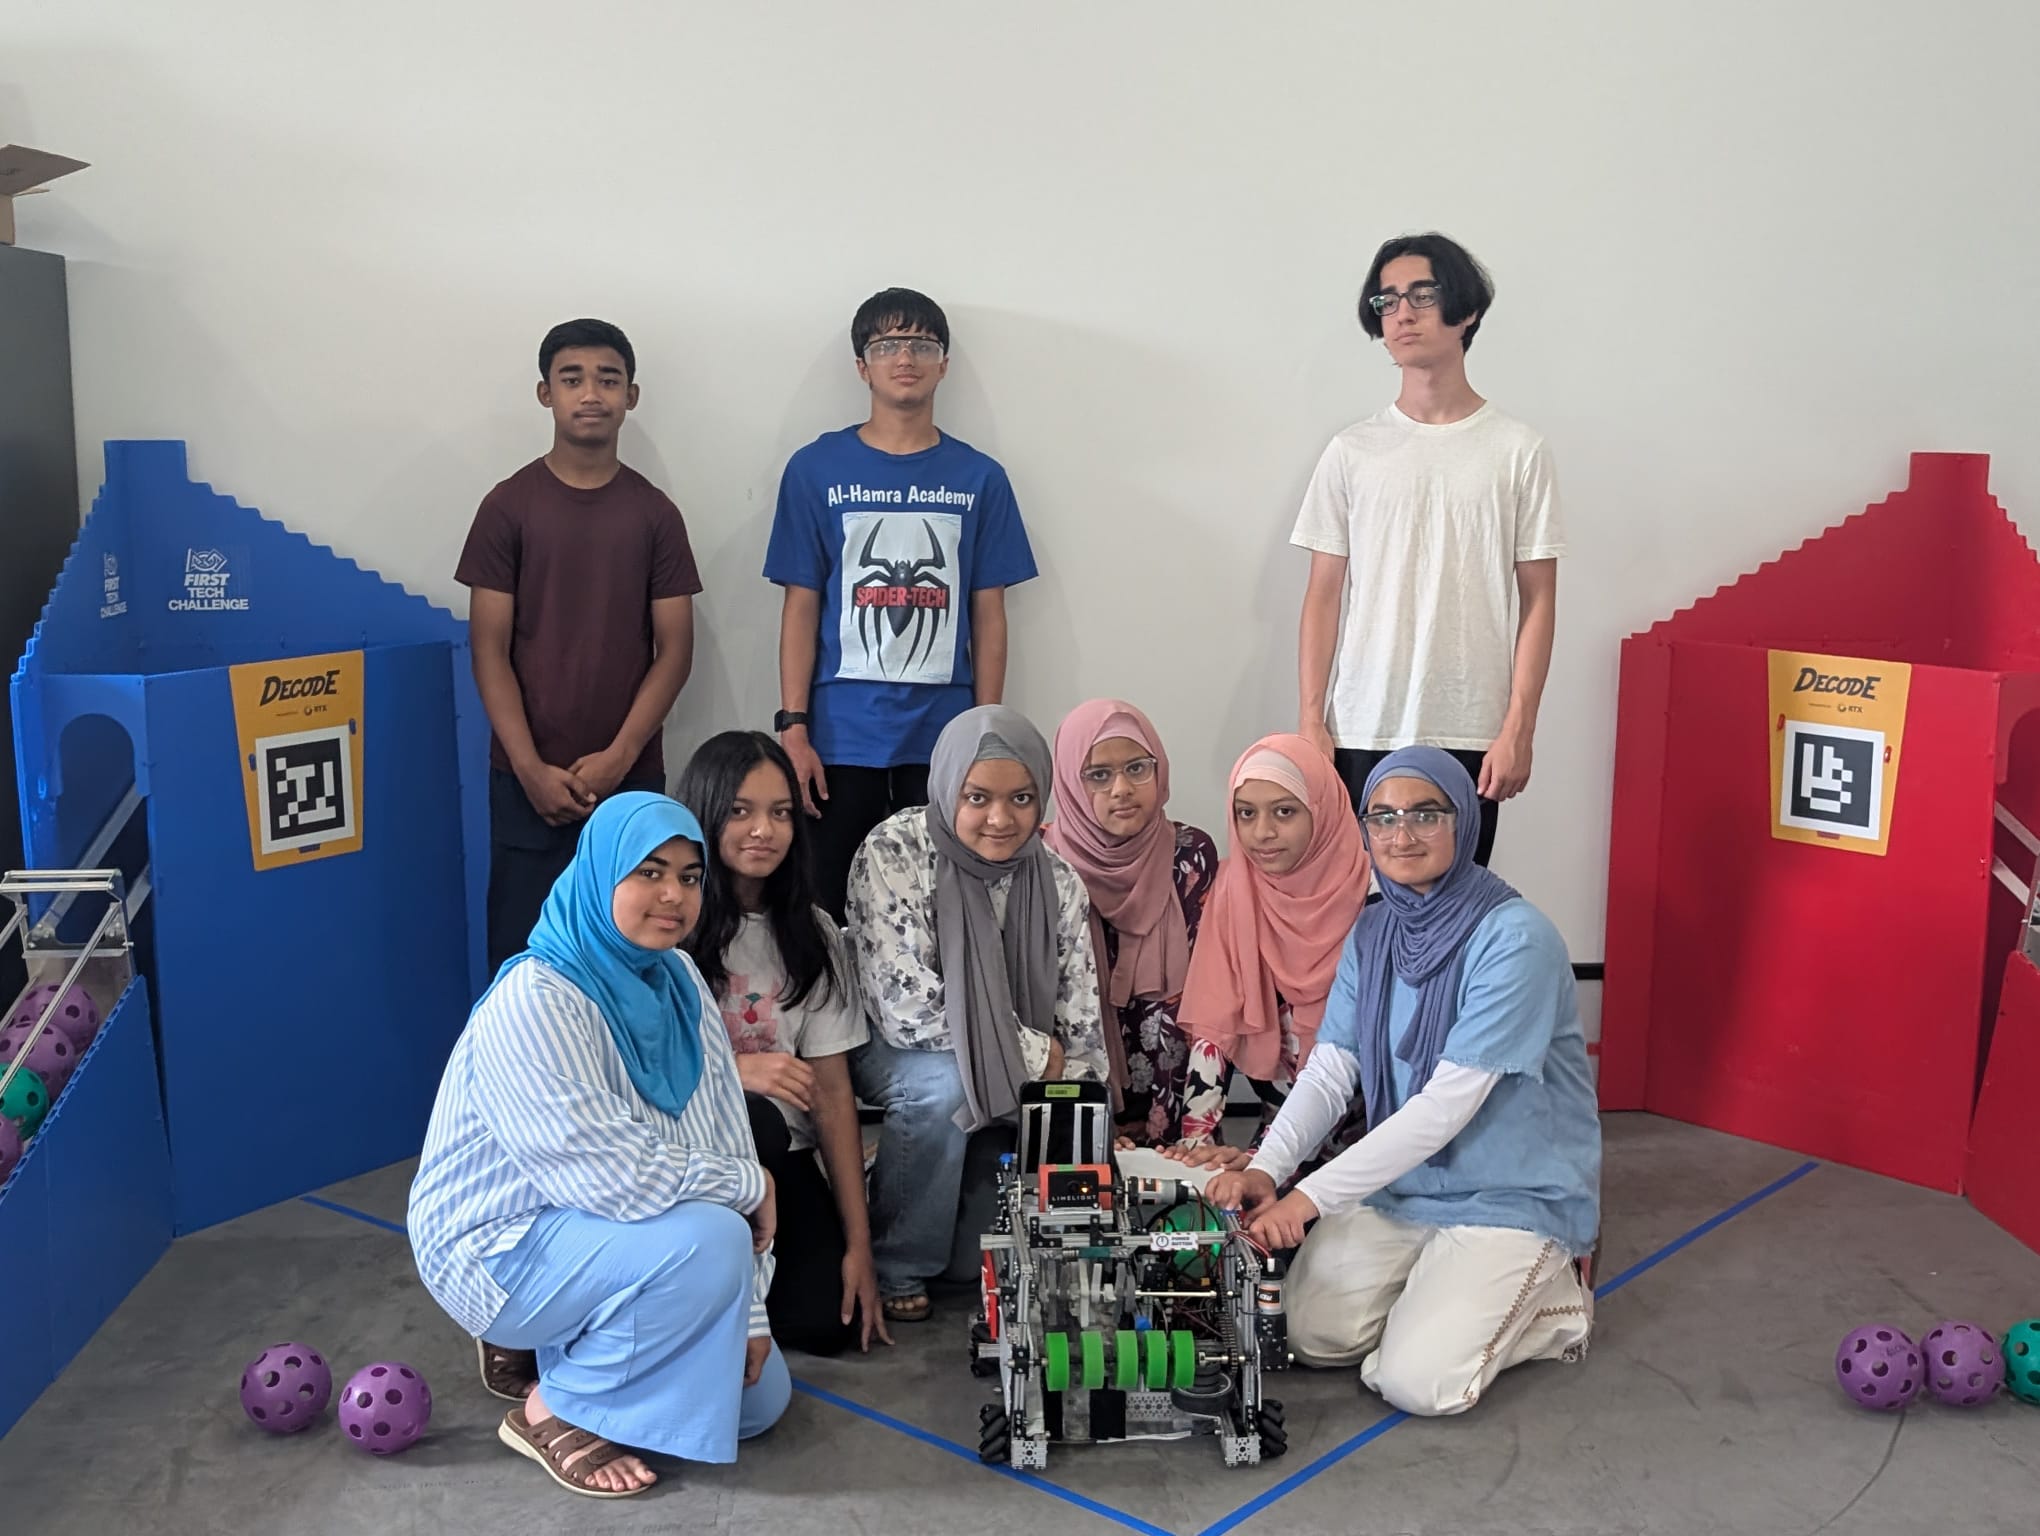
FTC SpiderTech Team Photo
Nameer
Hardware Manager
Nameer is the team's youngest member and serves as Hardware Manager, building, testing, and organizing the robot alongside others. He also leads the team's image, creating team videos, designing T-shirts, and helping develop the team logo.
Aydin
Communication Manager
Aydin is the team's Communication Manager, keeping everything organized both online and behind the scenes. He manages the ClickUp workspace, tracks team progress, and captures the robot and team moments through photography and videography. He's known for his attention to detail and impressive precision with cutting.
Taha
All-Rounder
Taha is the team's All-Rounder, jumping in wherever he's needed, whether that's hardware, software, or strategy. He's known for being hardworking and always willing to put in extra time to get the job done right. Taha also keeps the team's energy up with his humor, making even the longest build sessions more fun.
Nashmia
Software Engineer
Nashmia is the team's Software Engineer, responsible for writing and debugging the code that drives the robot. She's hardworking and dedicated, often spending extra time refining the robot's programming to make sure it performs reliably. Her problem-solving mindset makes her a key part of the team's success.

Seasons

Decode

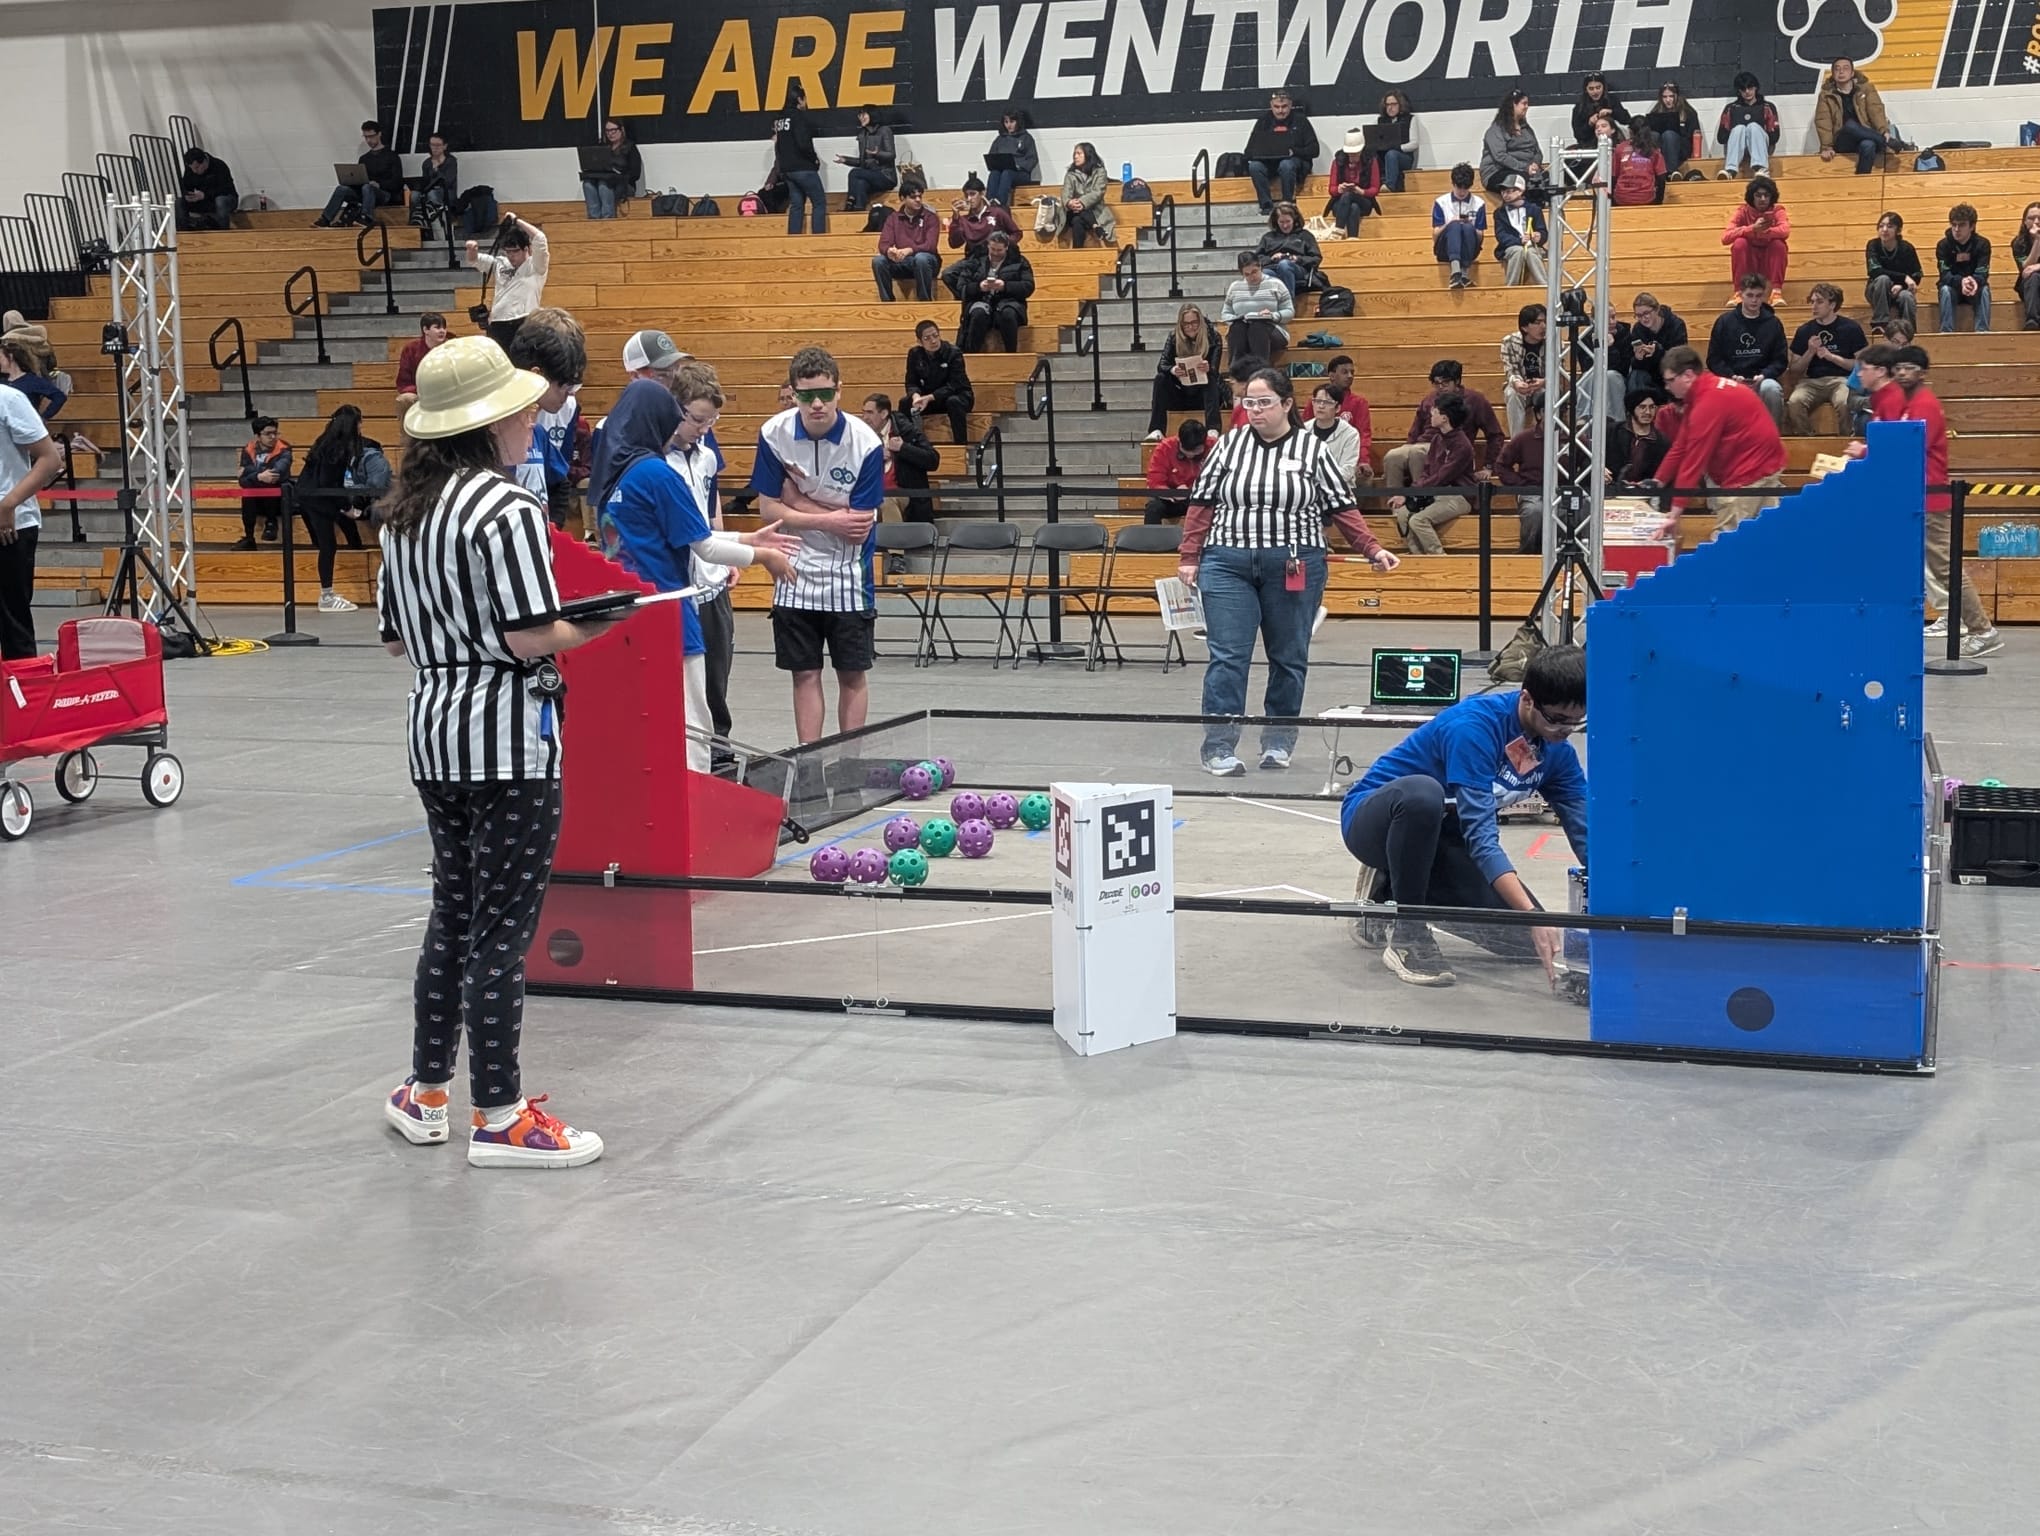
Decode was our rookie year as a team. We used materials from REV for building our robots. We competed in 2 qualifiers, earning the Connect Award in the former, and the Think Award in the latter. For a more detailed overview of our season, take a look at FIRST FTC Events Page.

Mass State Championship Connect Award Think Award

Hardware

Robot Iteration 1

Iteration 1

Read Description
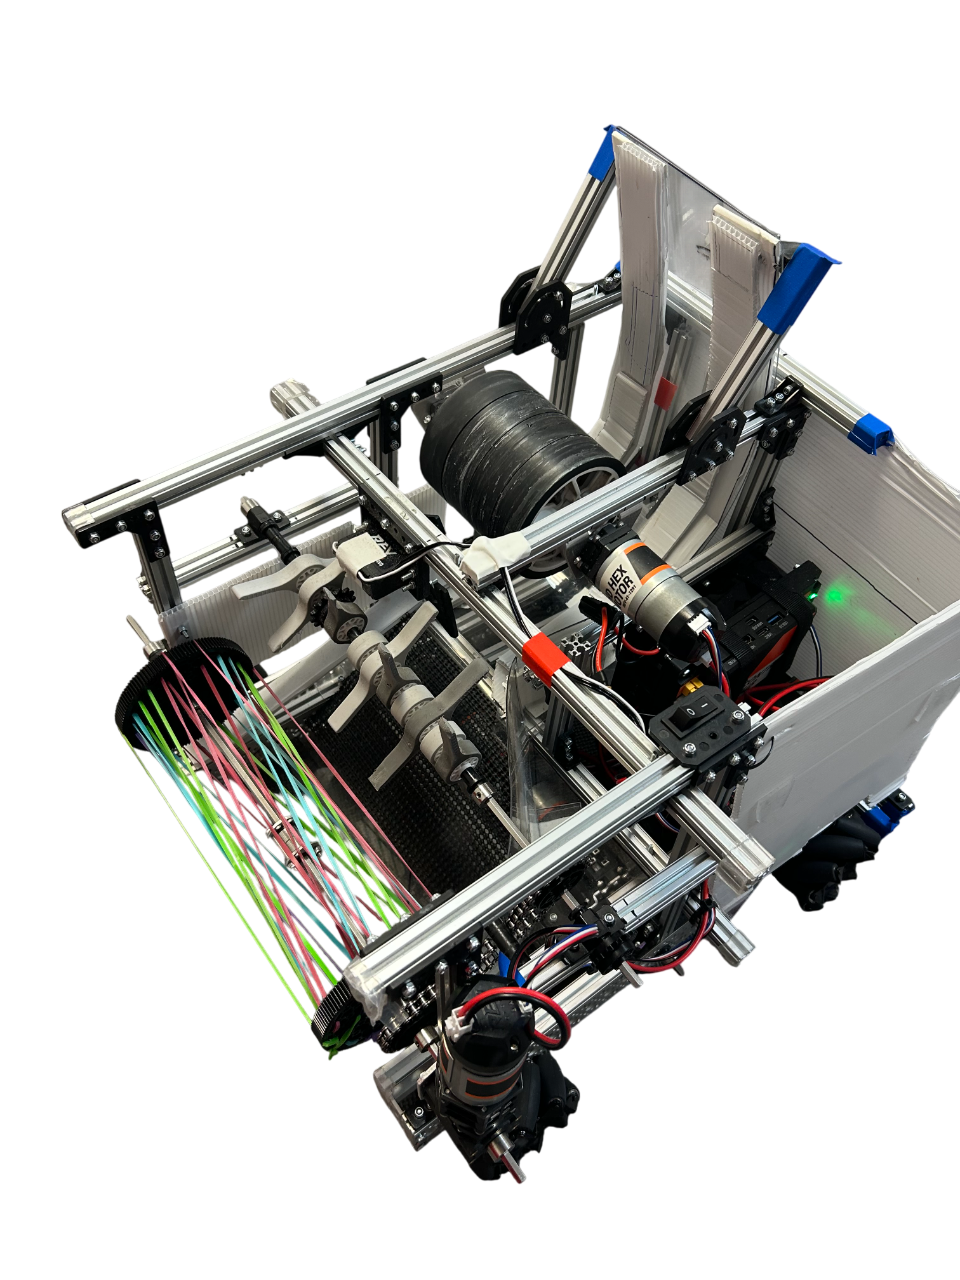
Our initial robot was primarily made of REV parts, with a heavy metal base and 4 wheels. The two front wheels were omnidirectional wheels, while the rear two were grip wheels, all coupled together with a system of chains. Our intake included a ramp with two rows of flap wheels that pushed the artifacts to a servo motor up top, which opened and closed on command. Opening the servo motor allowed the artifact to be pushed up to a row of 4 flywheels to be shot out through the ramp at the top.
Robot Iteration 2

Iteration 2

Read Description
For our second iteration, we made major modifications. We changed all 4 wheels to Mecanum wheels to increase the efficiency of the robot's movements. Additionally, we added a layer of foamy material on the ramp to increase traction between the balls and the ramp surface, ensuring a smoother journey up to the servo. Our first layer of flap wheels was swapped out with a rubber band roller intake system, allowing the robot to latch onto artifacts much more efficiently on the field.
Robot Iteration 3

Iteration 3

Read Description
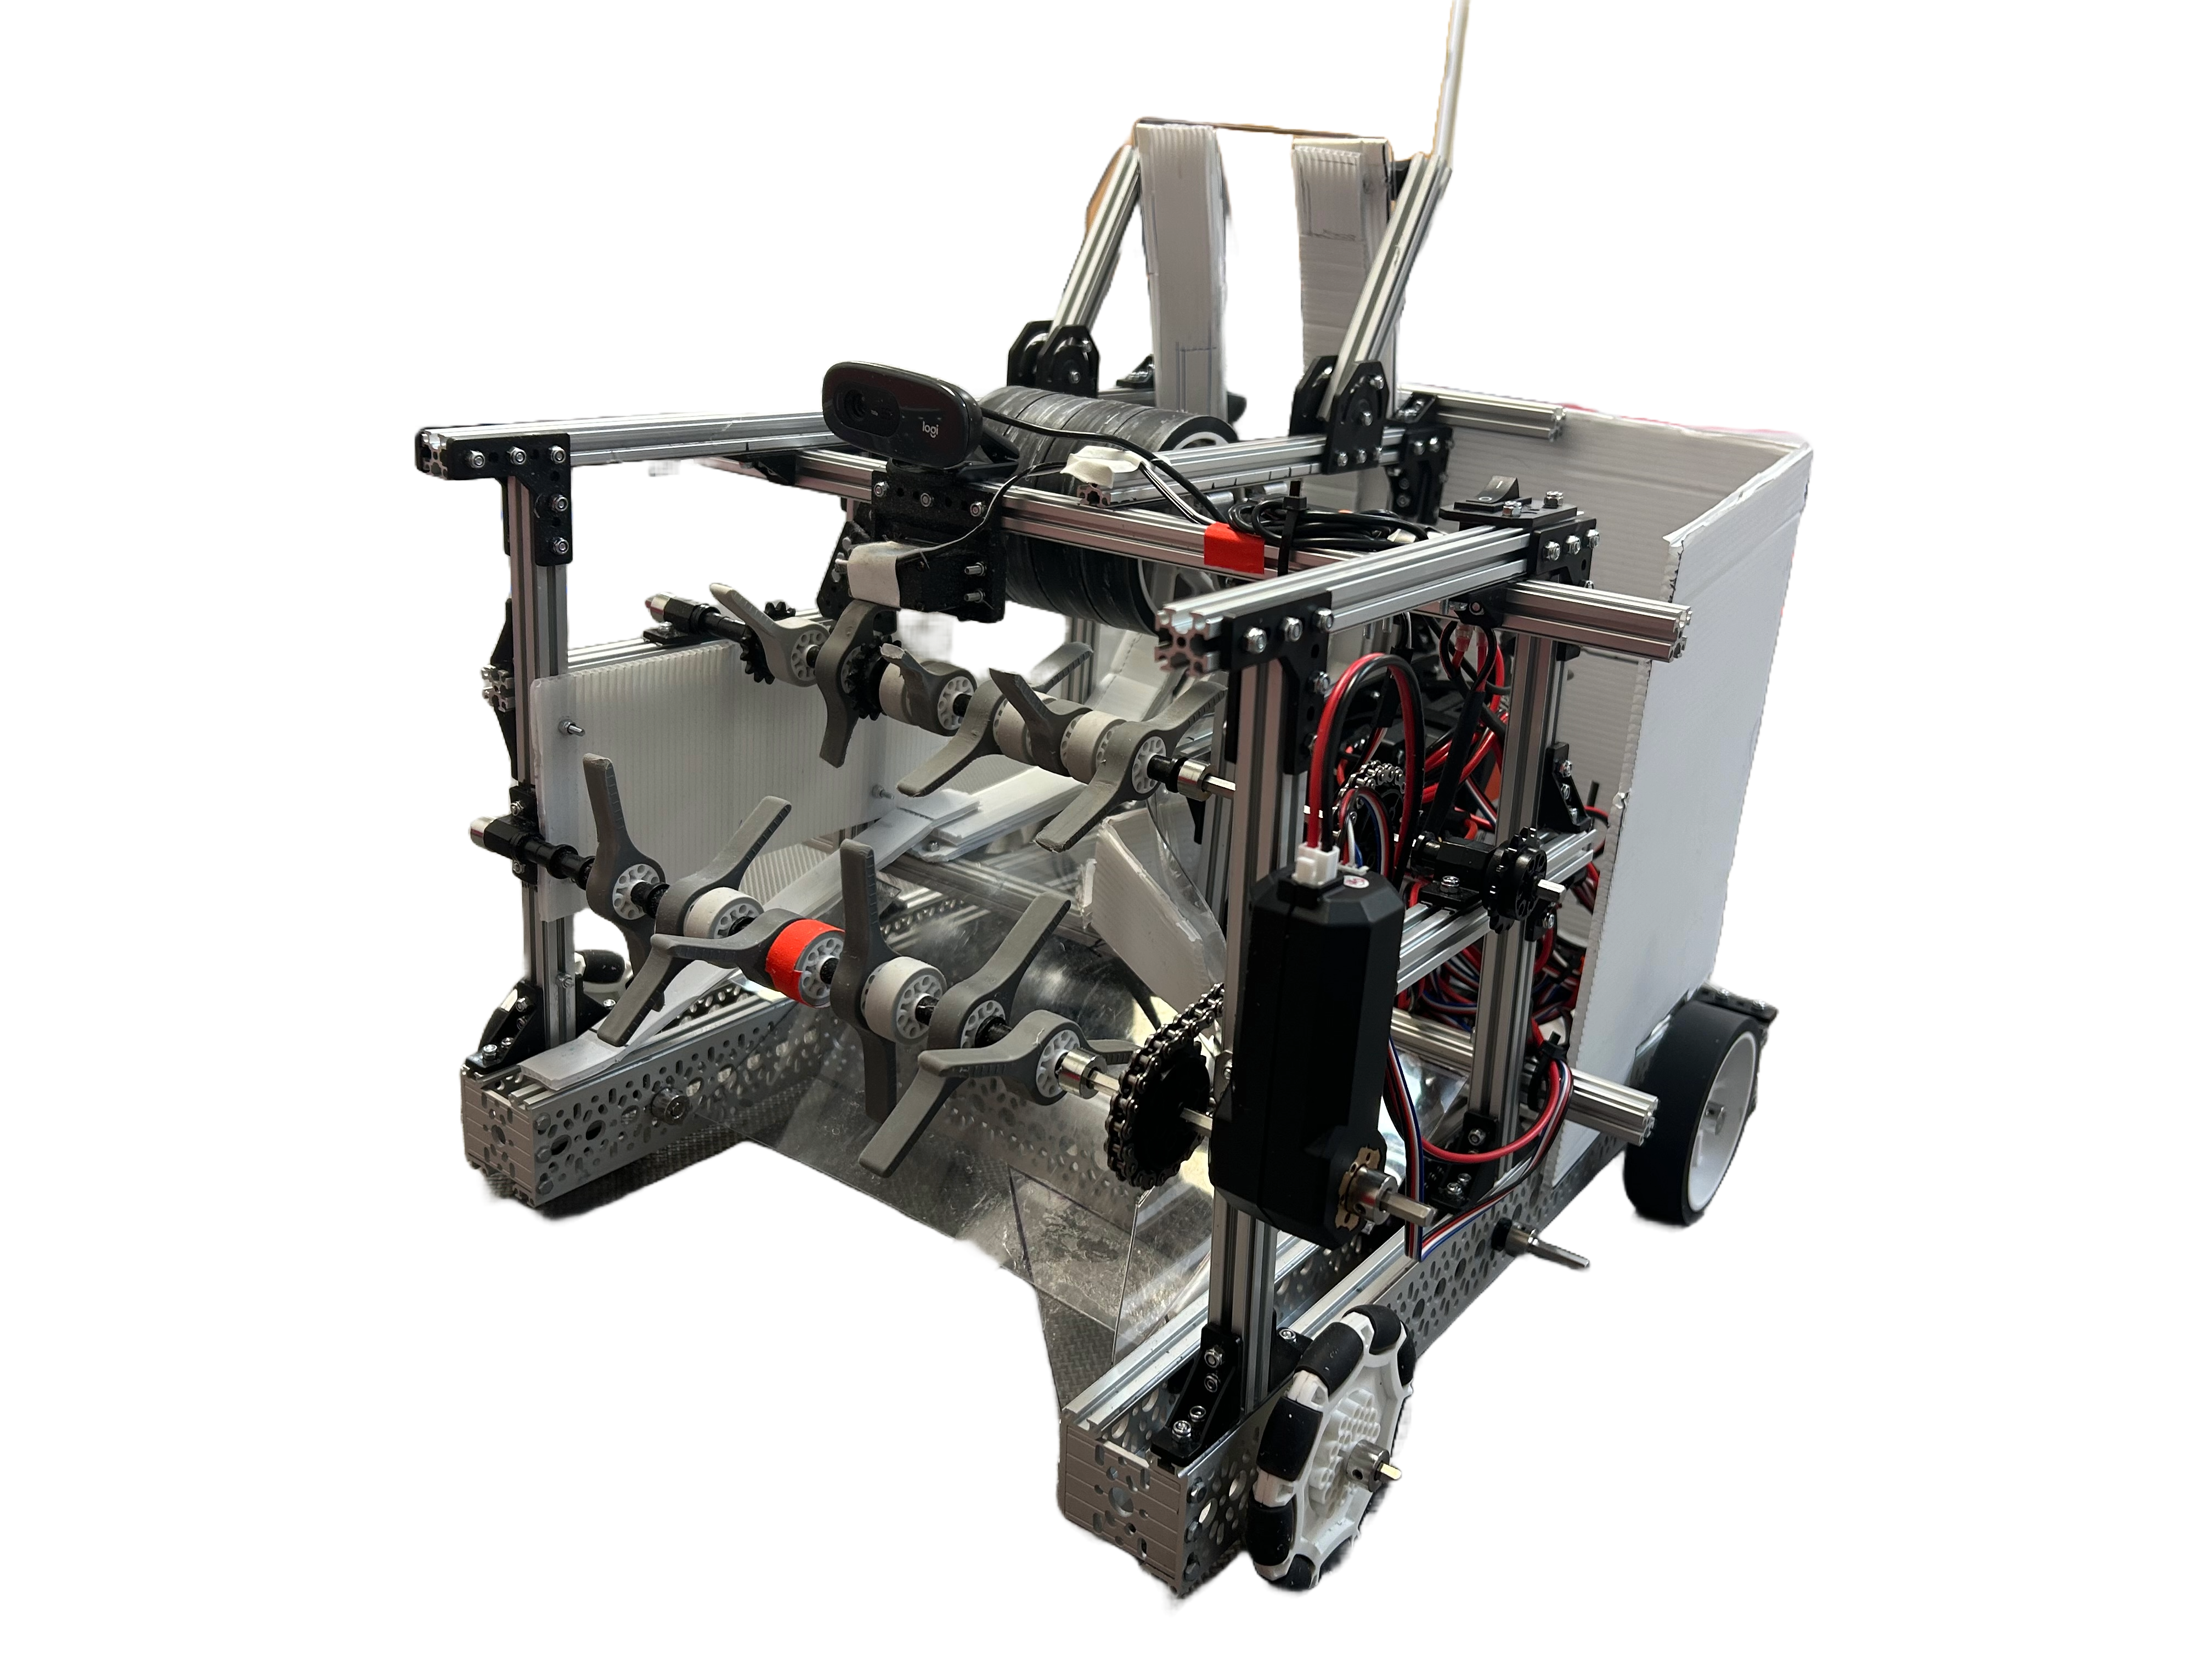
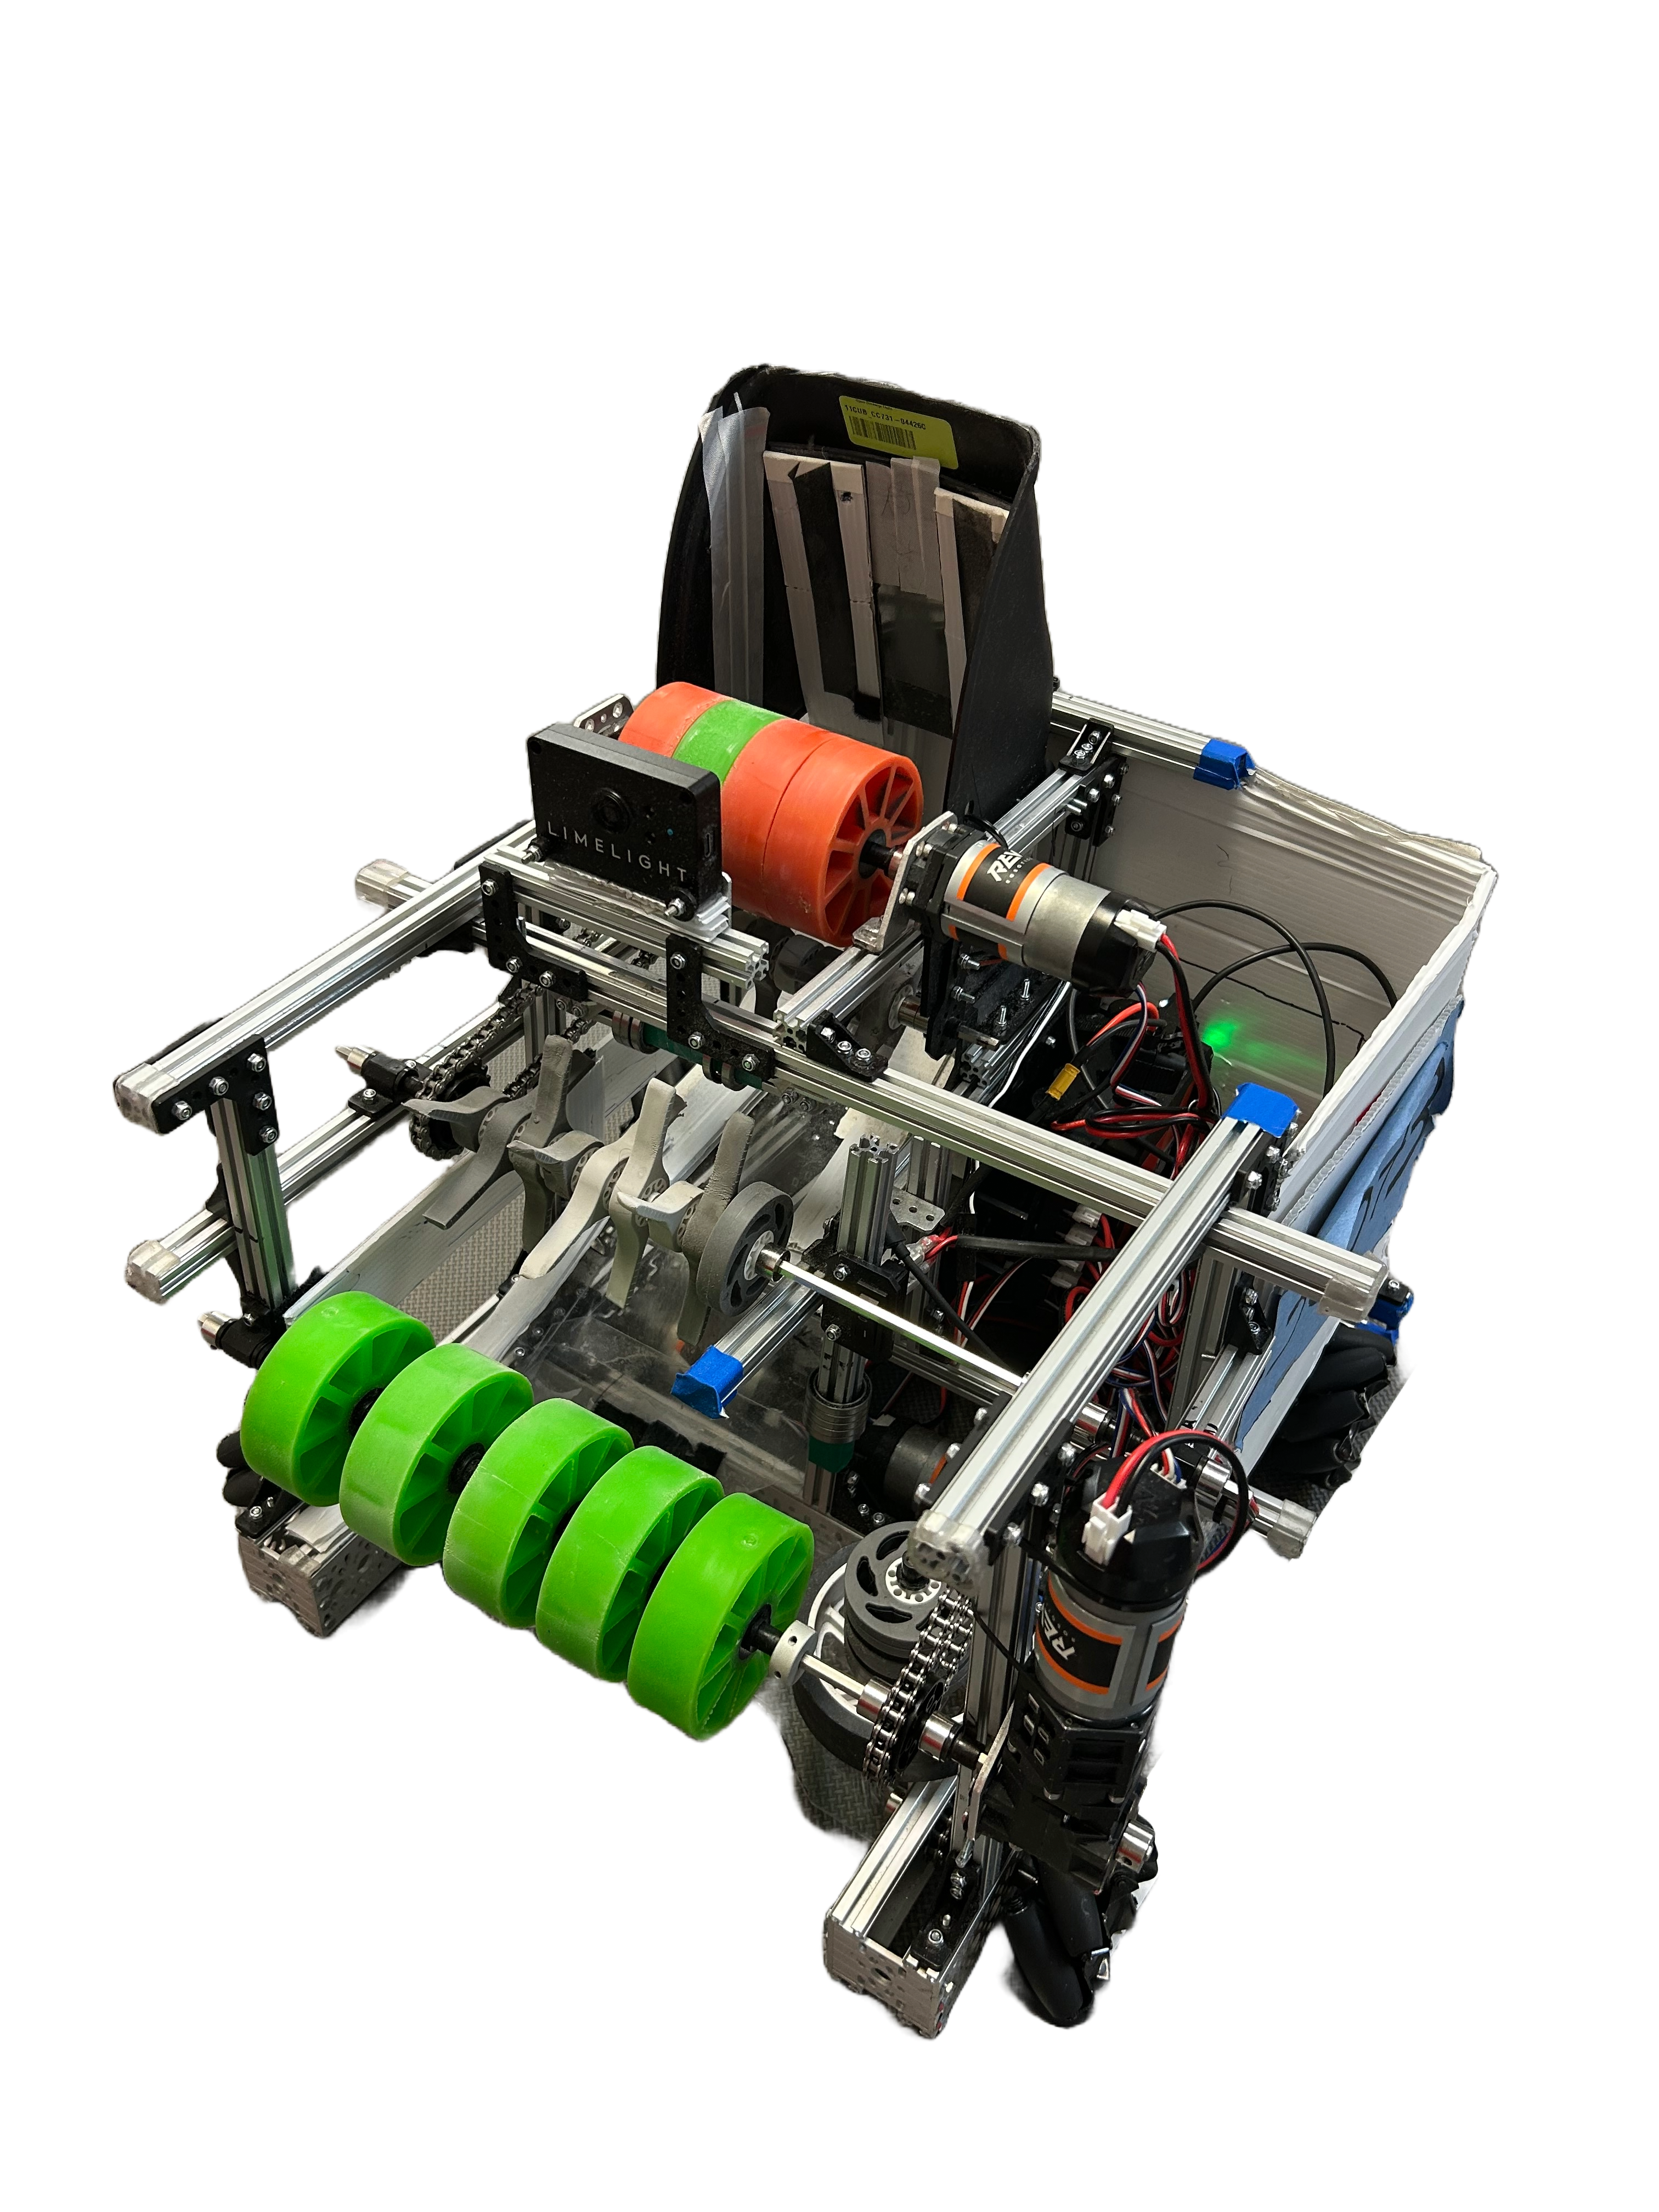
This iteration had the most significant changes to both the intake and shooting mechanisms. Our rubber band roller intake was replaced with a line of low-durometer wheels because the rubber bands proved too fragile and often tangled with other robots. These low-durometer wheels gripped the artifacts much stronger when intaking them. We also replaced our 4 high-durometer flywheels with lower-durometer wheels to reduce excessive pressure on the balls when shooting. Our last major change was adding a camera, which significantly helped us locate, collect, and shoot artifacts efficiently into the goal.

BioBuzz

We were at the season kickoff! Right now, we are analyzing different startbots and brainstorming ideas for the season. Stay tuned!

Kickoff Event

Resources

You can find the code from our Decode season here.

Outreach

Roboball
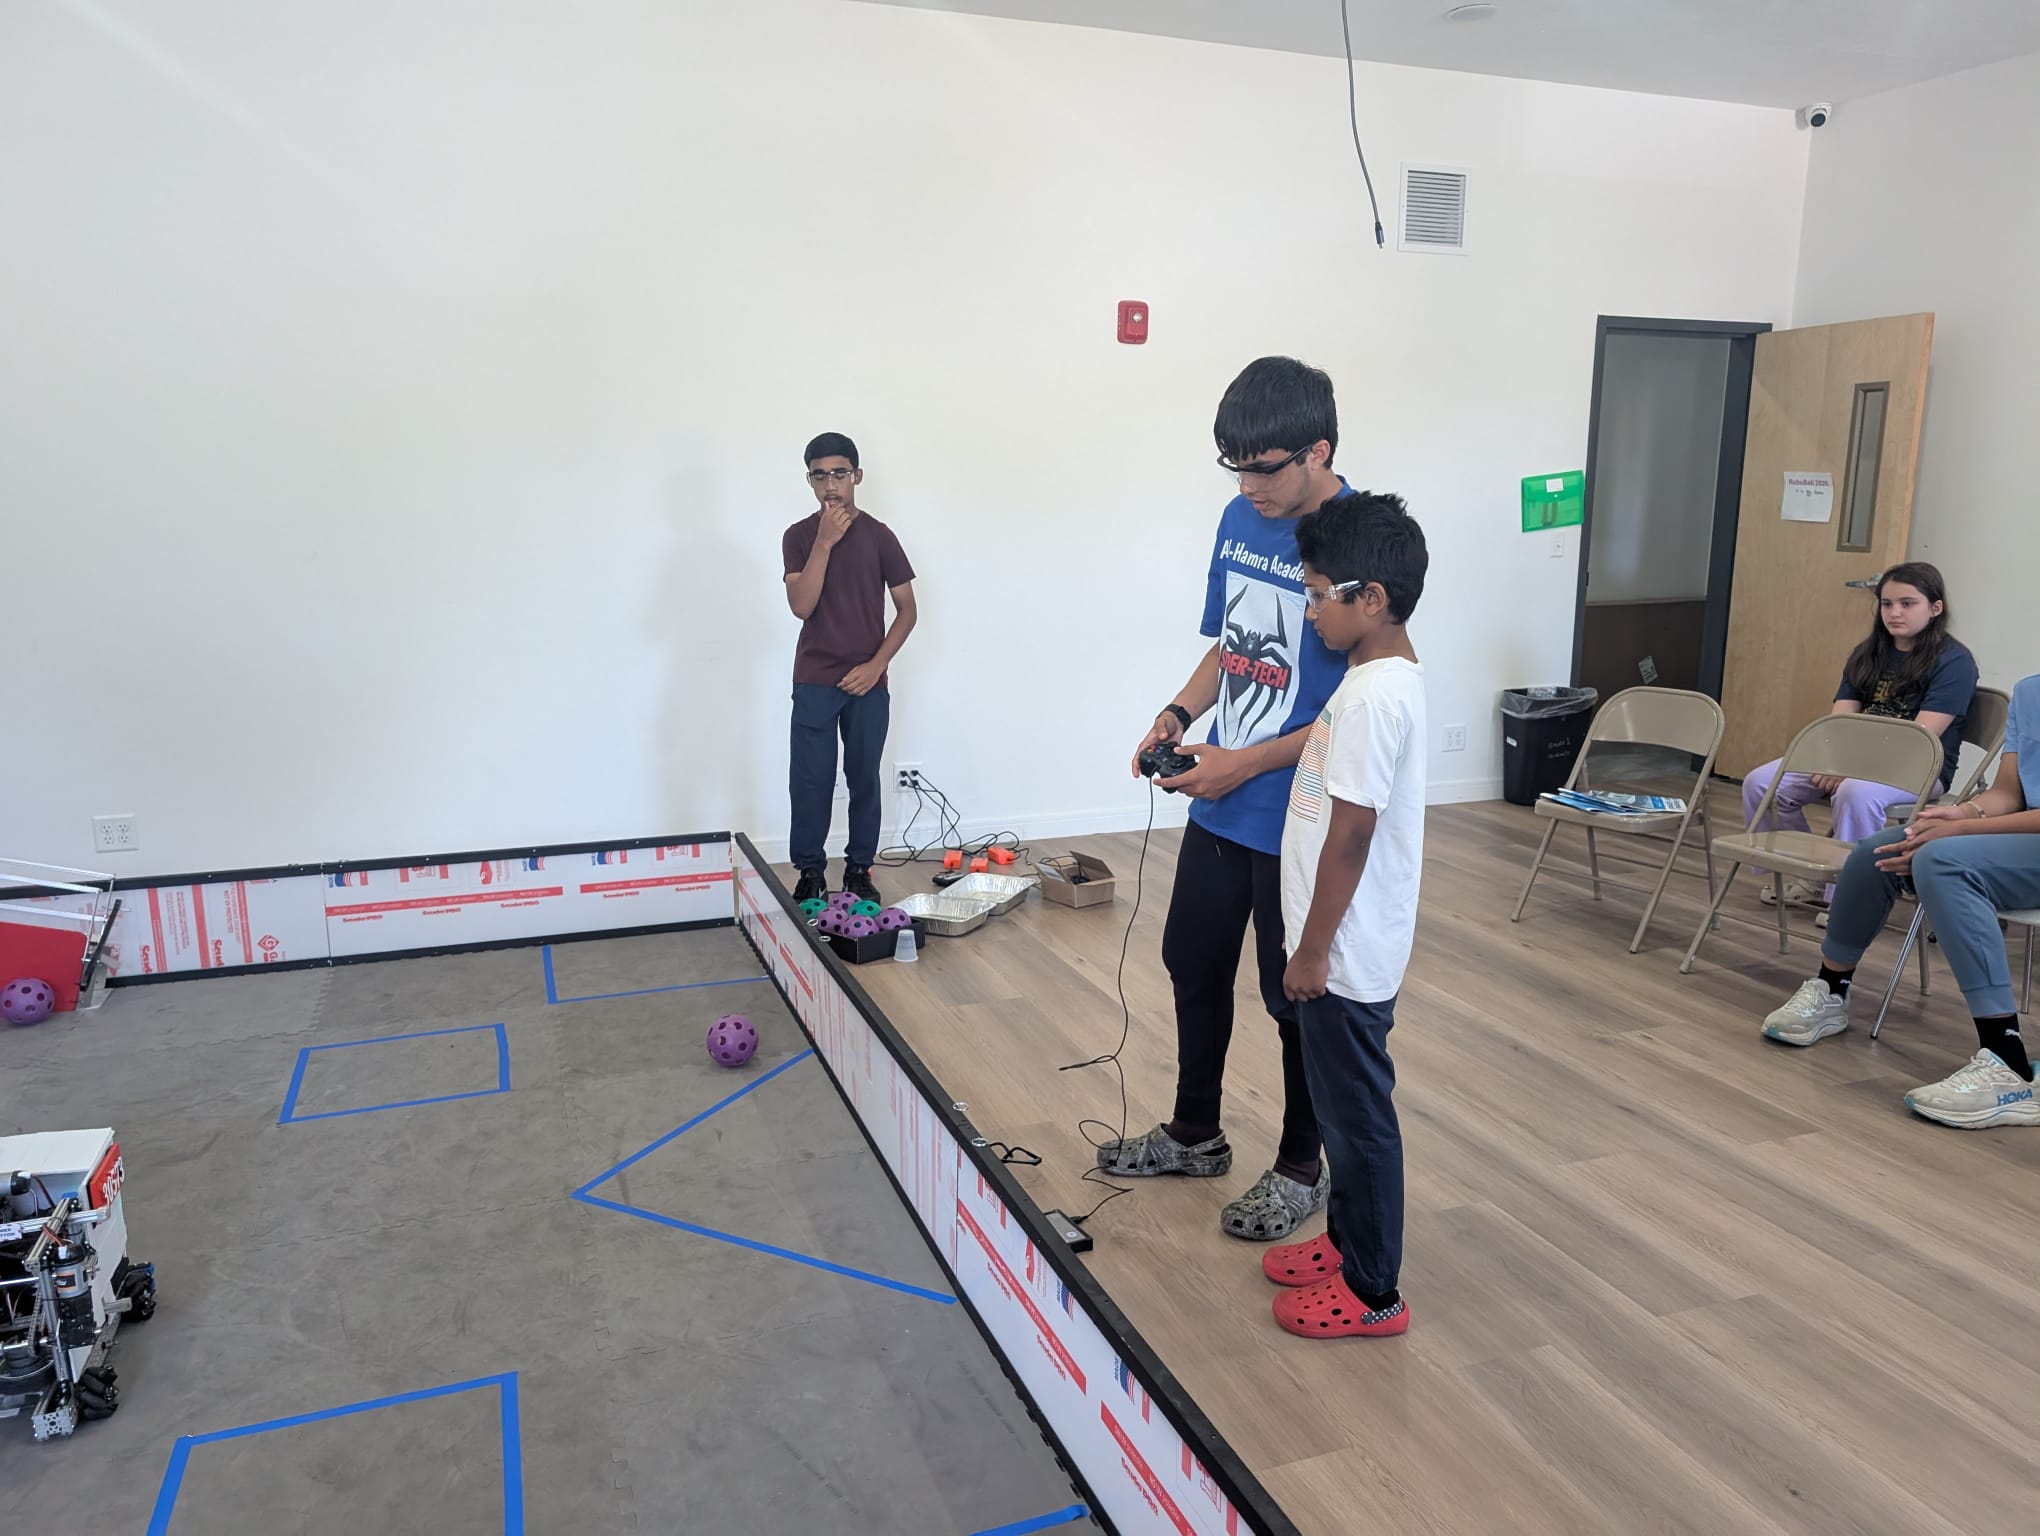
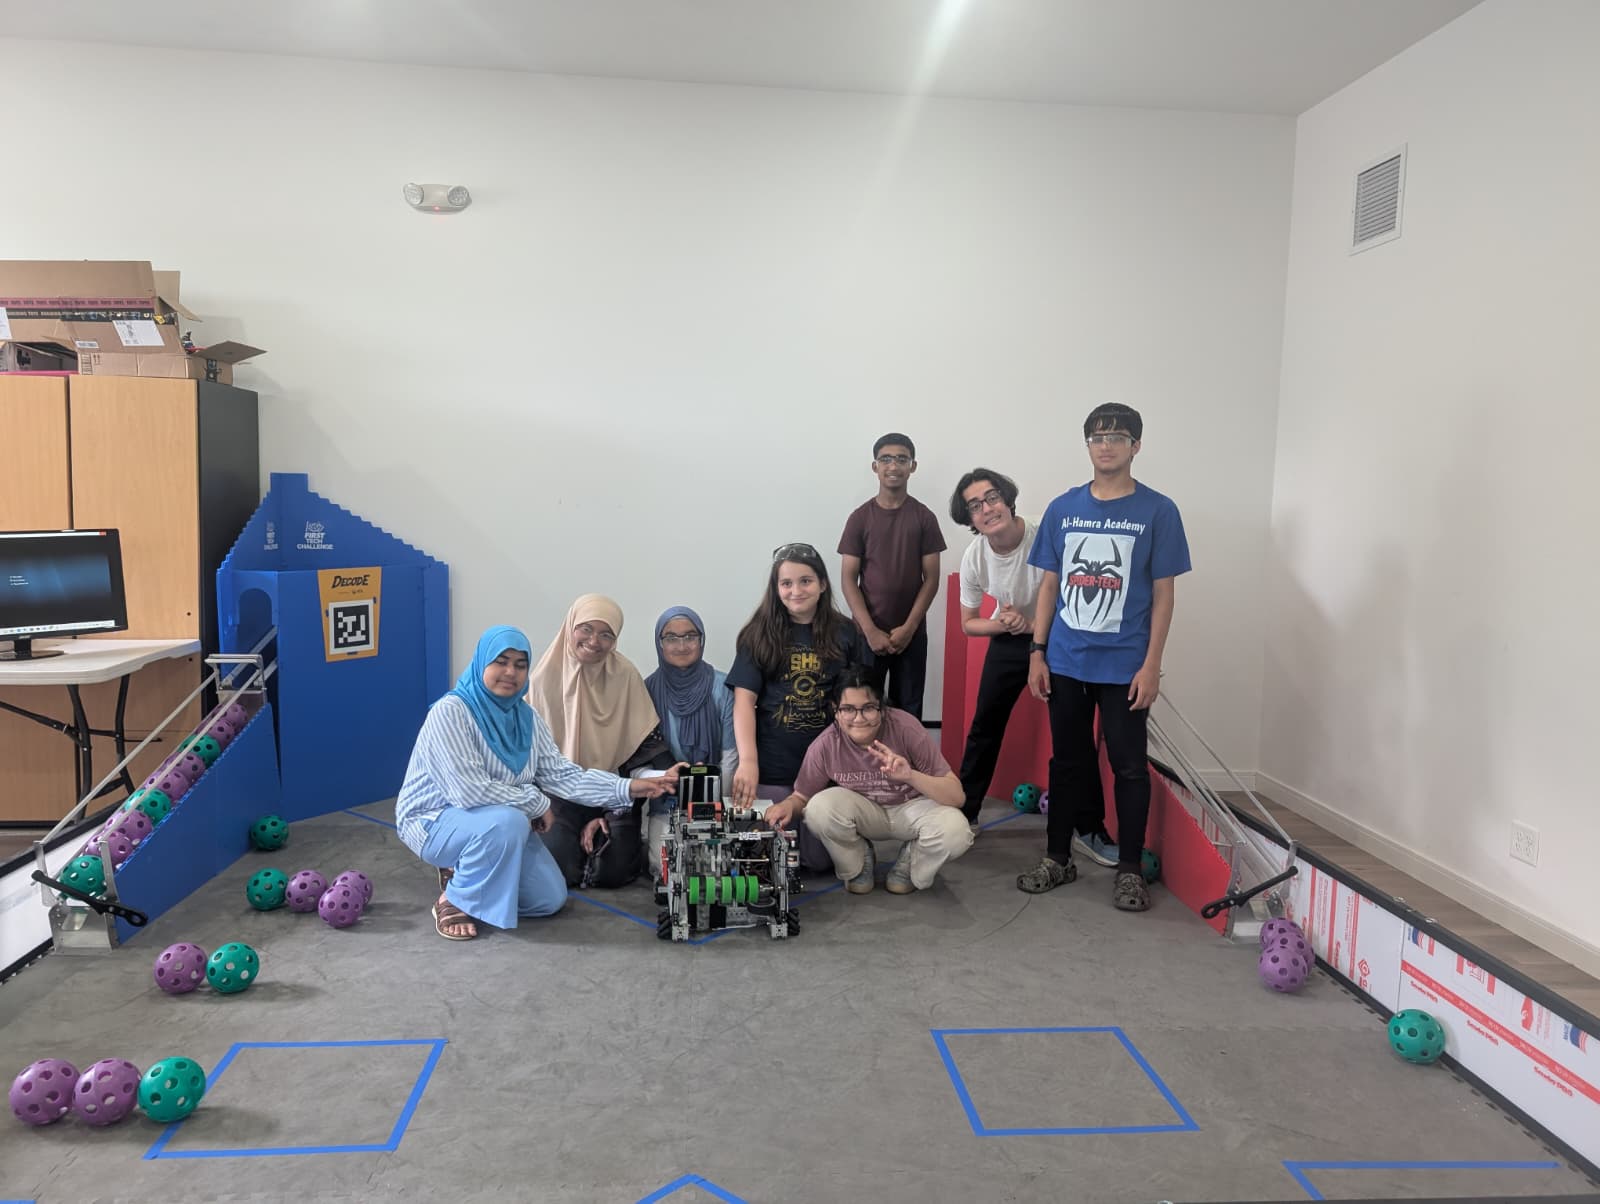
In May 2026, we launched Roboball, a Decode inspired game for elementary and middle school students. We modified the rules, created new game strategies, and simplified the missions themselves to make it more engaging for younger students. As a team of 4, the planning was meticulous leading up to the event itself. Time slots, food management, and award distributions were finalized across multiple sessions, and eventually, our hard work paid off. 29 kids showed up throughout the 6 hour event. For more than half of these kids, it was their first time being exposed to robotics, and they enjoyed it thoroughly.
RoboBall 3 RoboBall 5 RoboBall 4 RoboBall 2
Shrewsbury Public Library Event
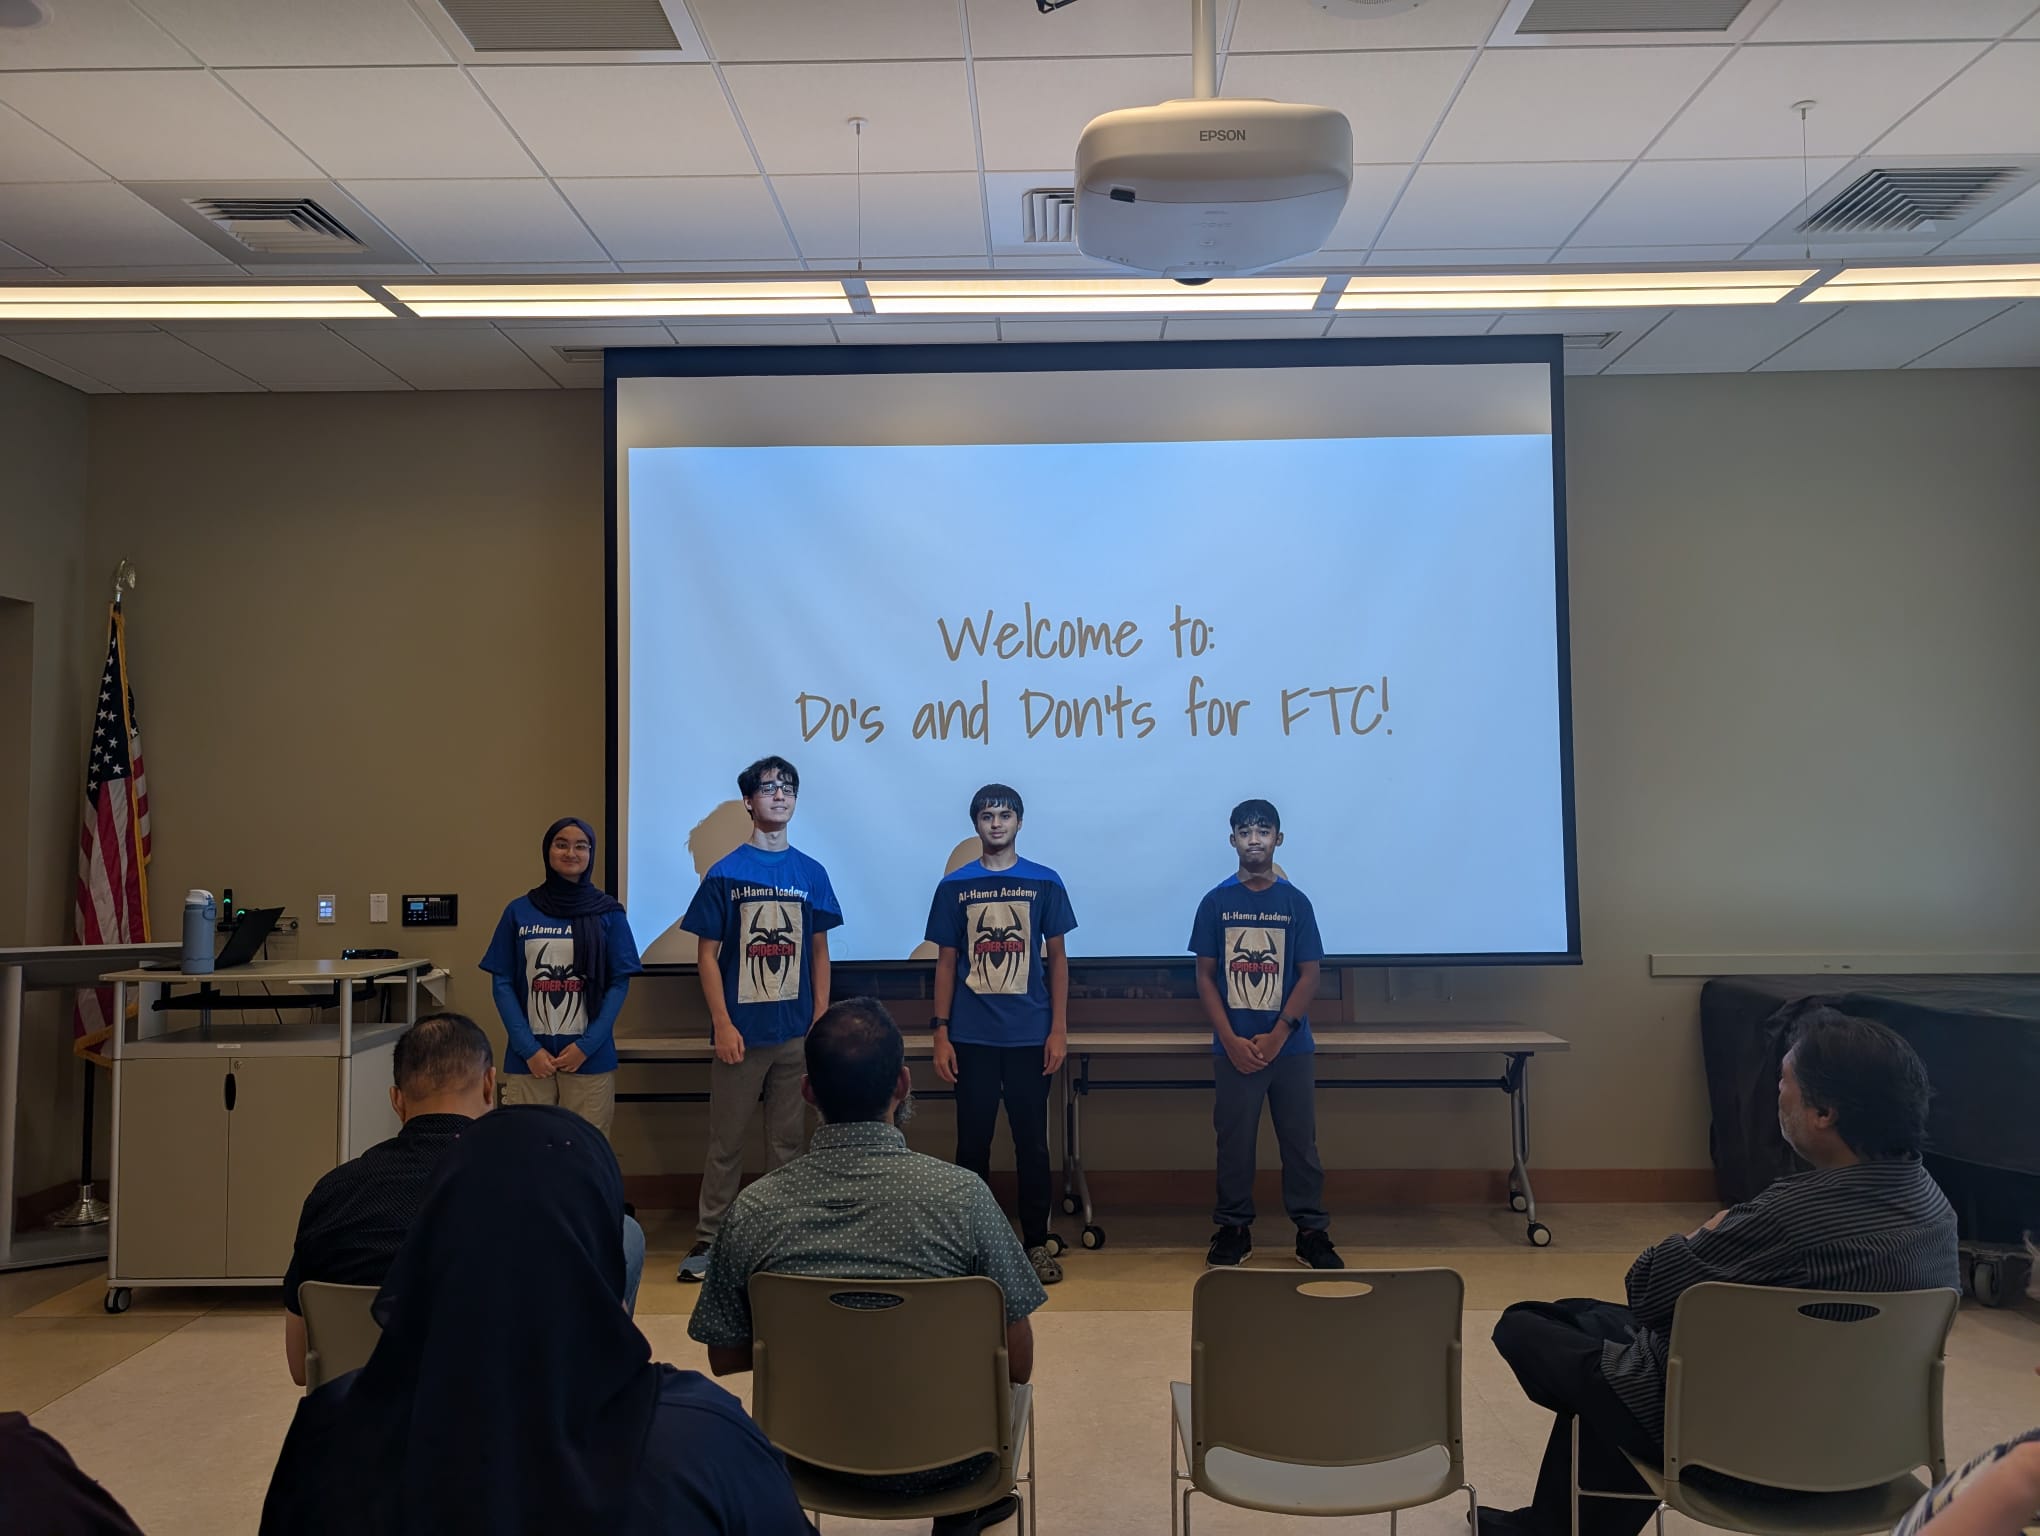
On August 8th, we held a teen teach event that focused on educating incoming FTC students and coaches on the Do's and Dont's for your rookie season. We discussed the mistakes we made in the hardware, software, and planning, and followed this by explaining what the proper way to complete these tasks would've been.
Shrewsbury Public Library Event